
University of Washington · Robot locomotion
UW builds a one-gram robot with controlled jump height
What happened
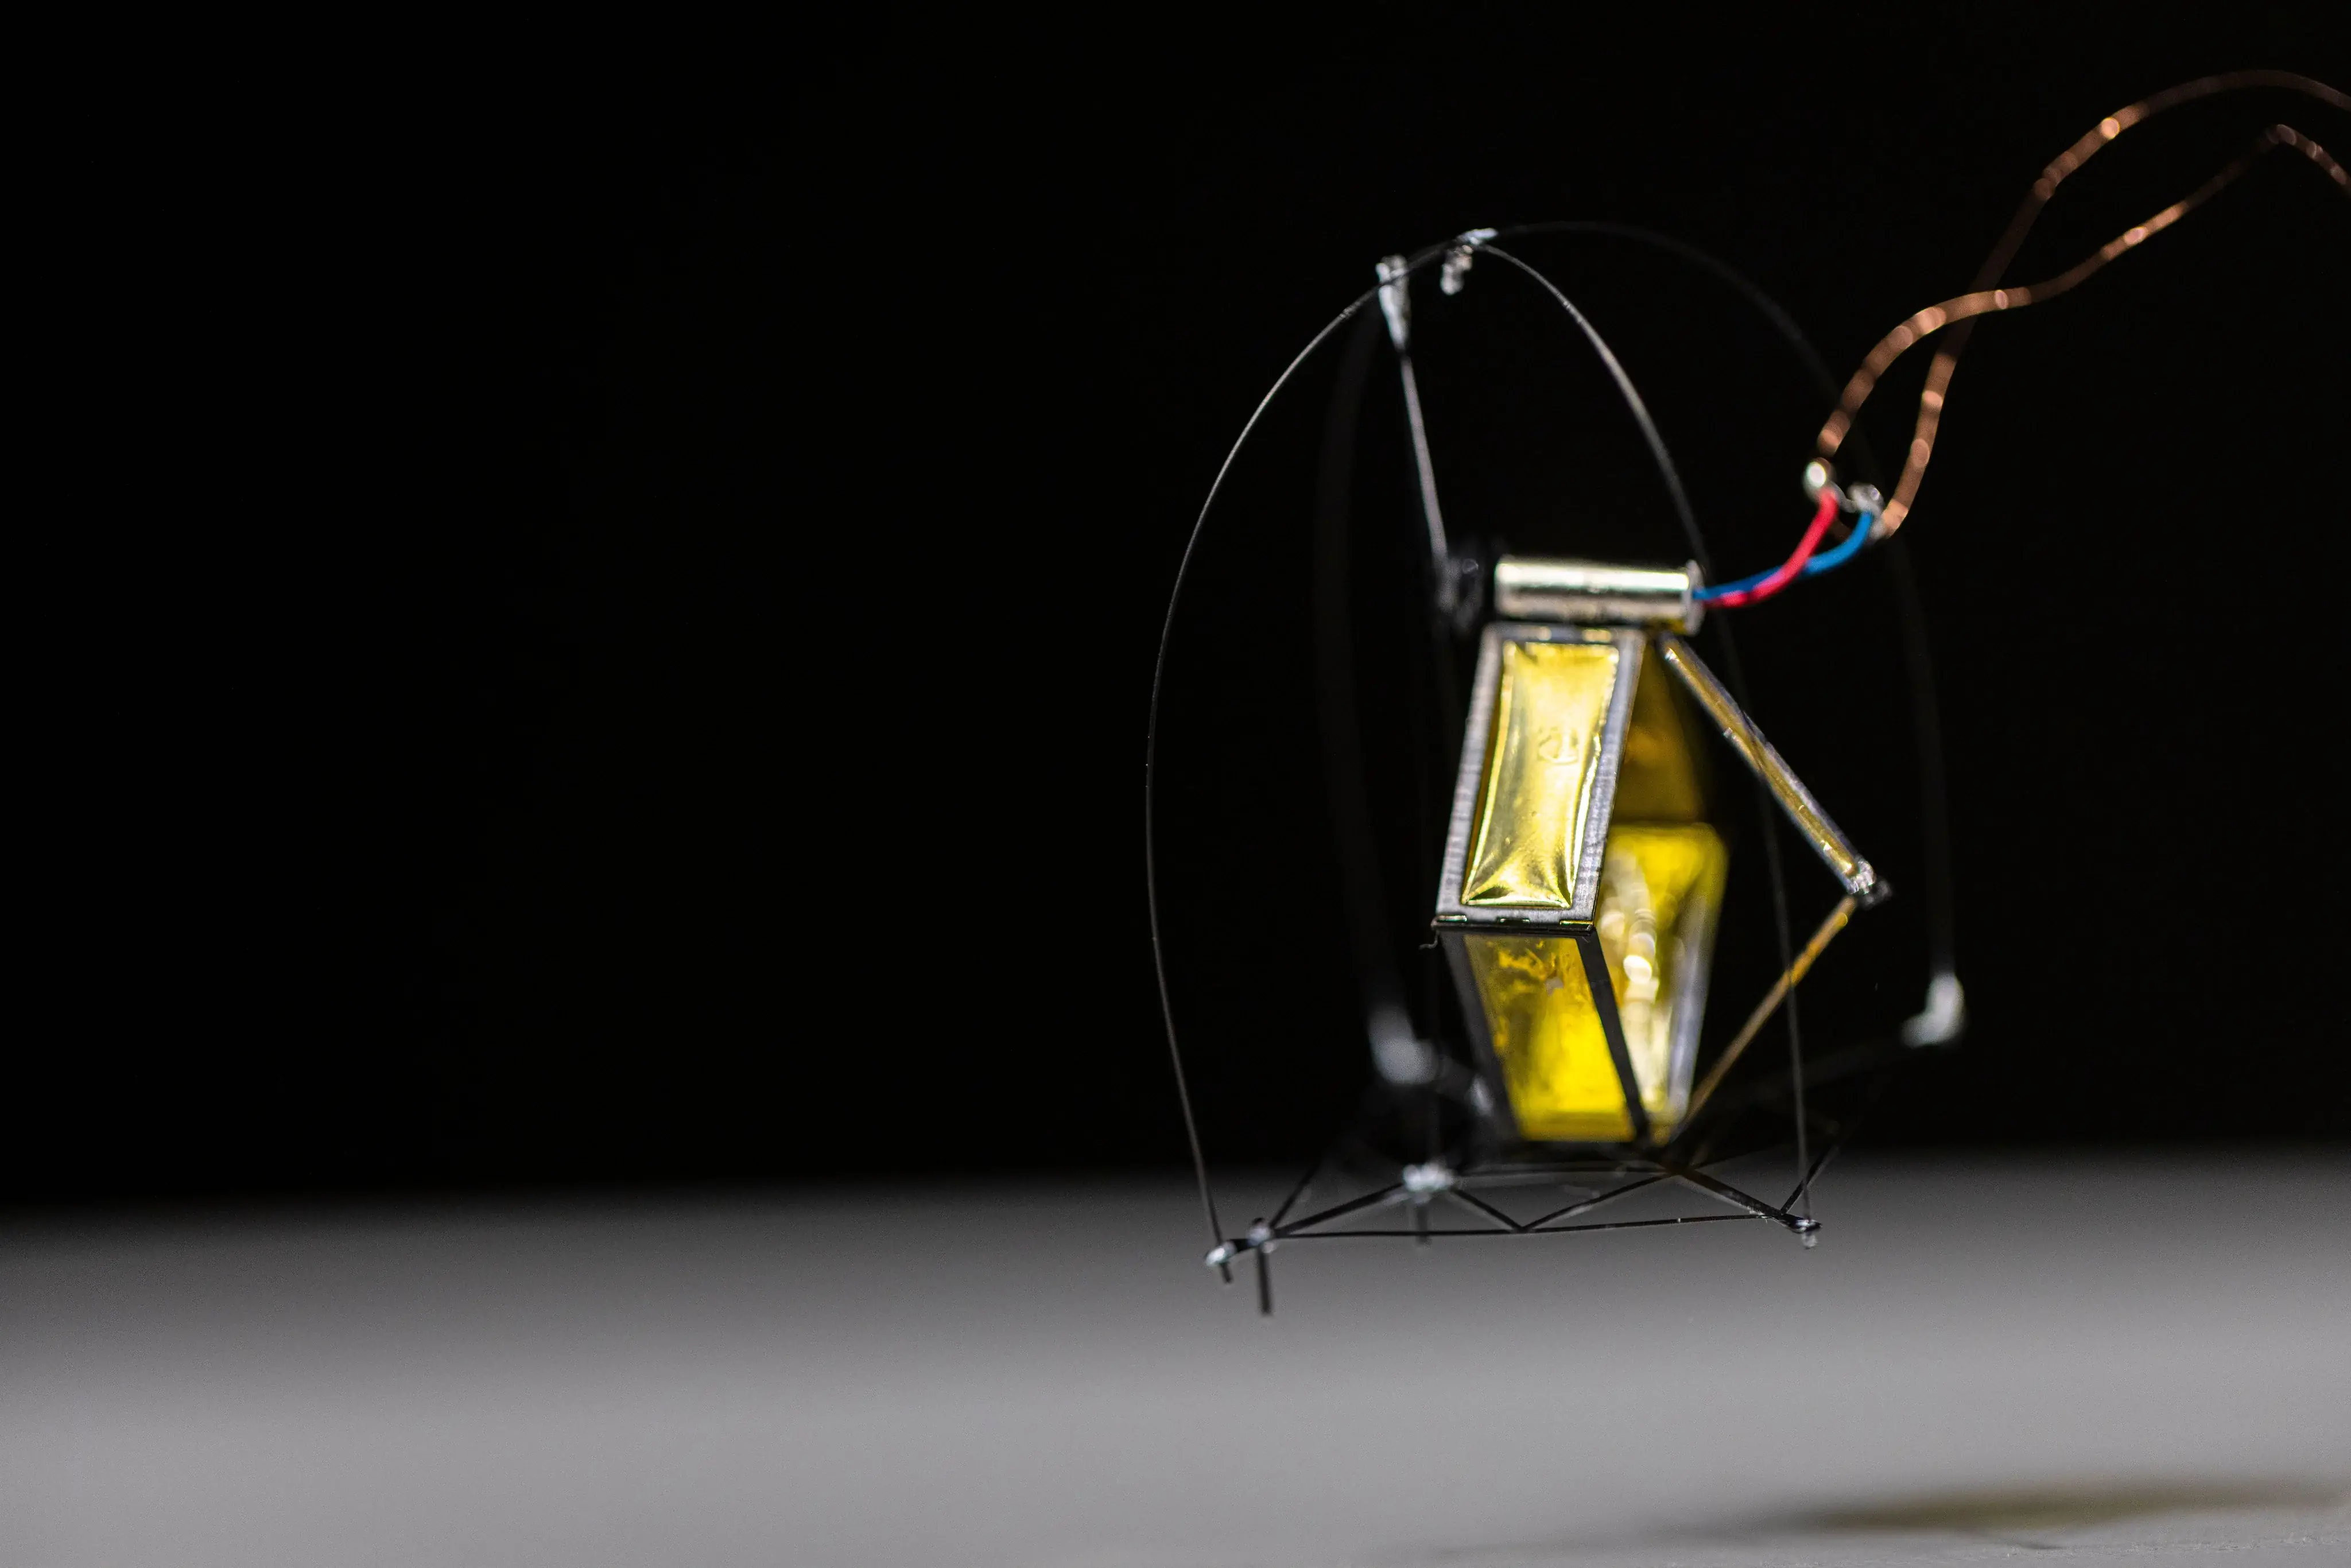
The University of Washington team demonstrated a roughly one-gram robot that can clear a standard stair step and self-right 90% of the time. Adjusting motor current changes the jump height, while three folding legs and a roll cage help the mechanism survive and reset between hops.
Why it matters
The design shows controllable jumping at very small scale, but it is not yet autonomous: the prototype receives power and instructions through wires and cannot steer. Onboard power, navigation and directed stair climbing remain future work.
Source checked October 31, 2026. Status describes the evidence in the linked source at the time of review.