
UCLA and University of Michigan · Robot locomotion
UCLA and Michigan build a snap-powered hopping robot
What happened
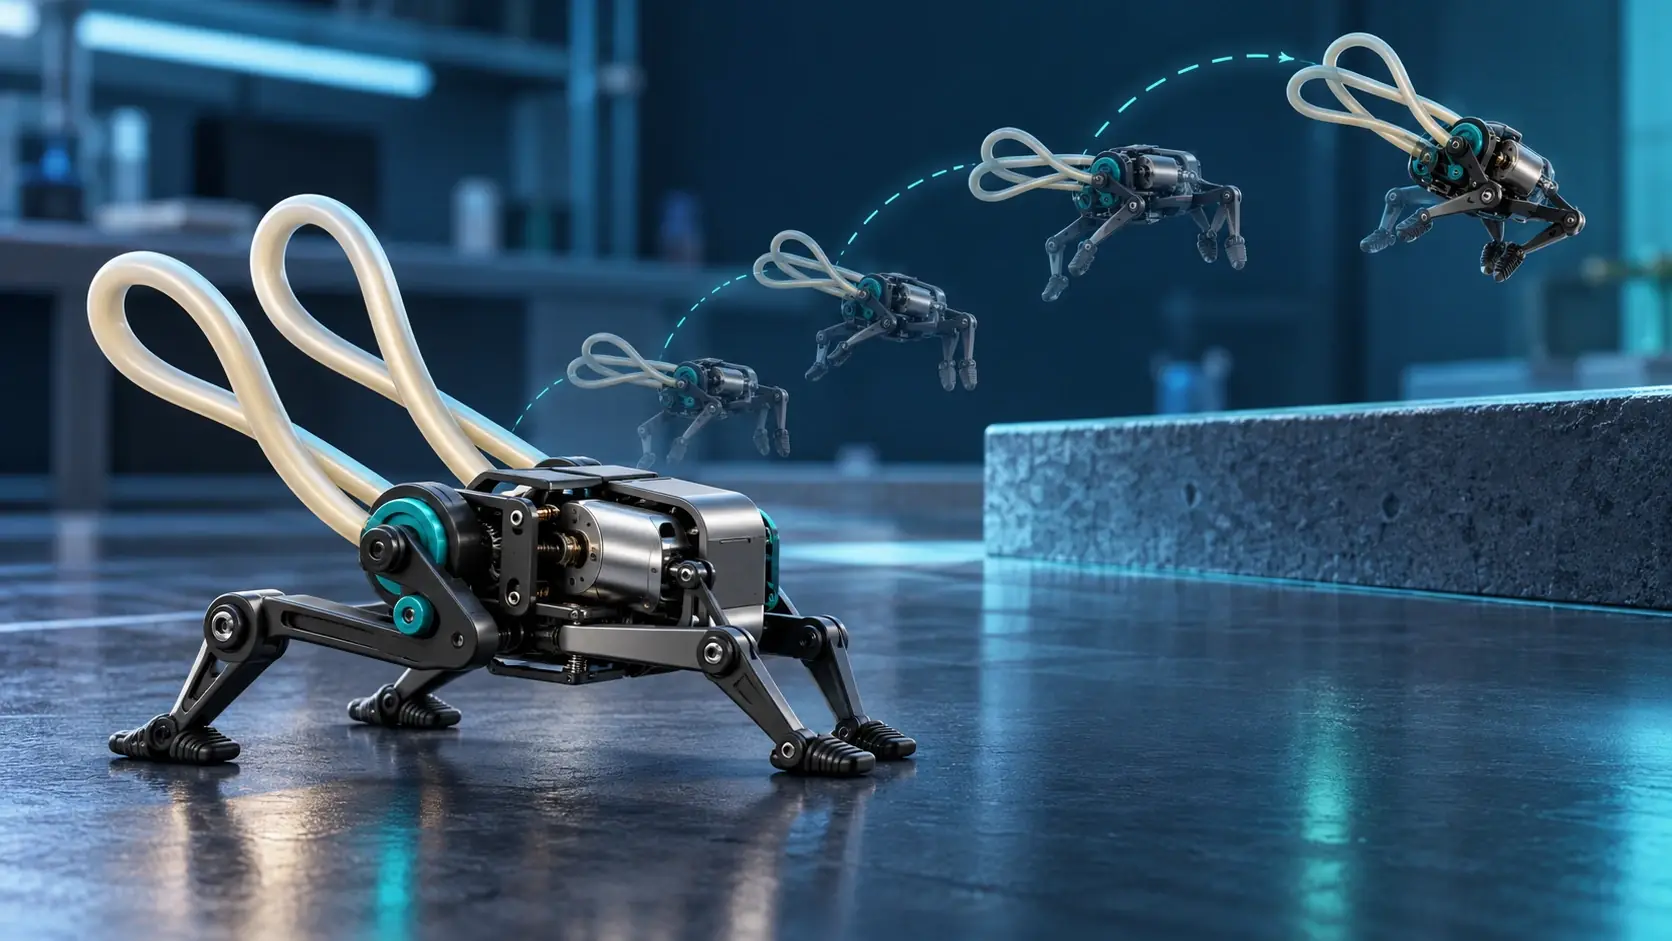
The team combined computational models with physical tests of bent and twisted elastic rods, then used the resulting design rules to build a 98.2-gram prototype. UCLA reports that it crossed six tested surfaces, reached a peak of 3.21 body lengths per second on wood and swam with added fins. The researchers teleoperated it through a rocky sandbox and separately demonstrated light-sensor steering.
Why it matters
Snap-through mechanics could give small robots stronger bursts of movement without continuously running a high-power motor. The evidence is a controlled research prototype, not an autonomous field deployment or commercial product.
Source checked October 31, 2026. Status describes the evidence in the linked source at the time of review.