
UC Davis + UCLA + MIT · Micro aerial robotics
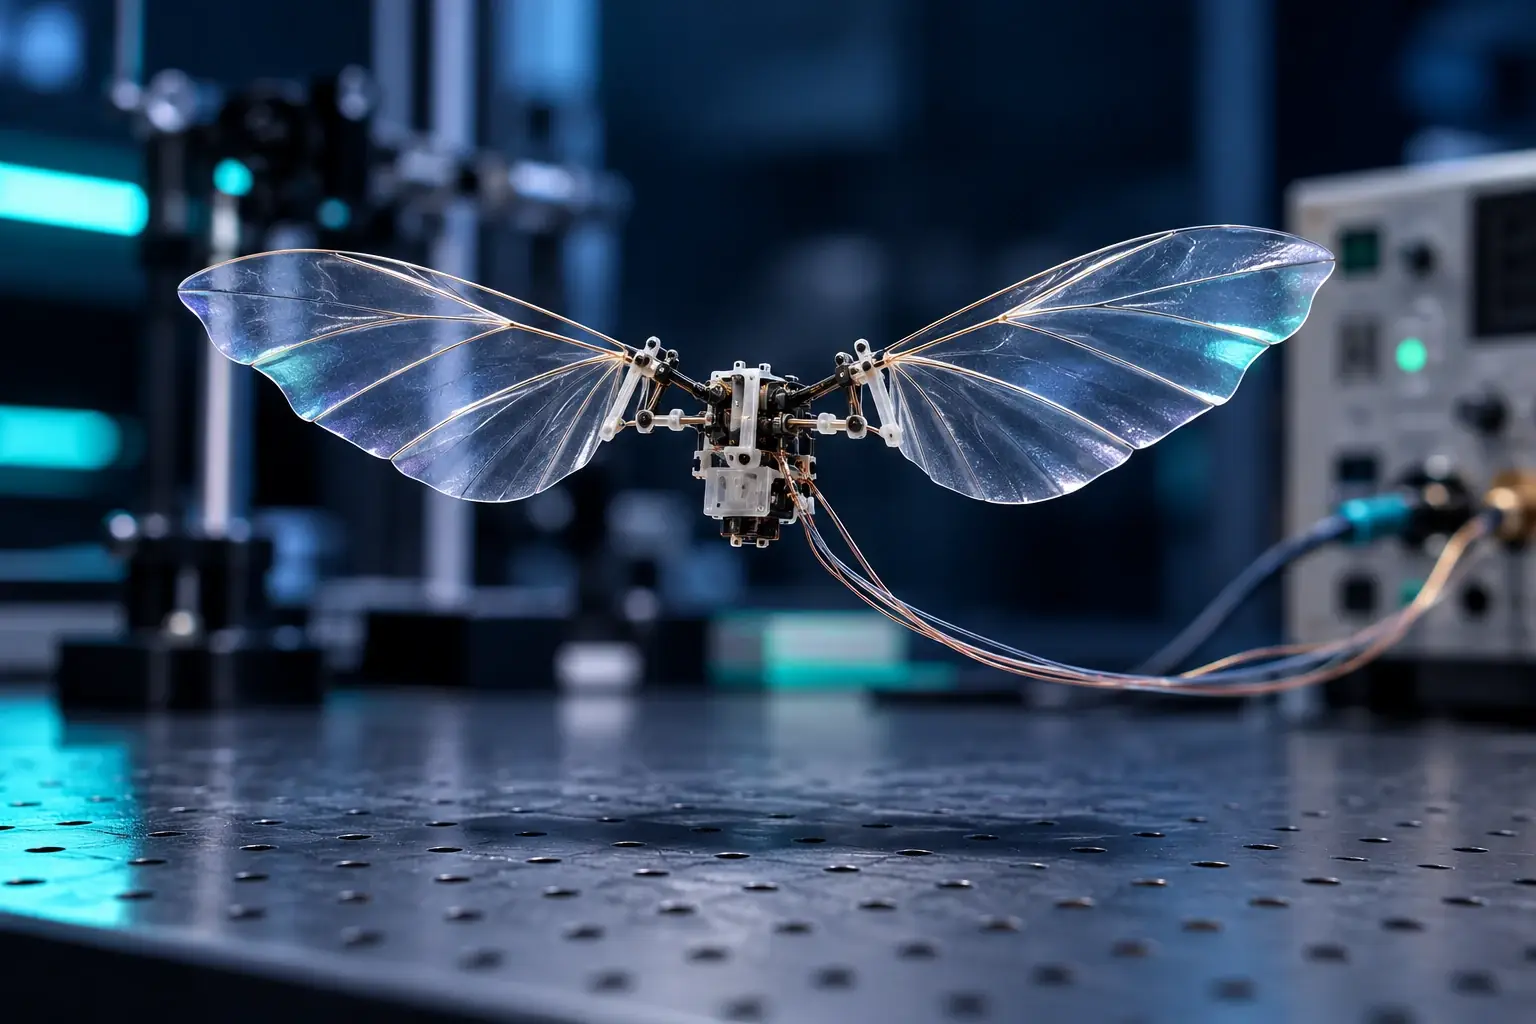
UC Davis team builds an impact-tolerant micro flying robot
What happened
The researchers used flexible polymer wings and an electrostrictive actuator. In physical tests, the prototype survived an obstacle collision, a flyswatter impact and flattening under aluminum blocks weighing 11,000 times its own mass, then resumed operation.
Why it matters
The design addresses the fragility that keeps many insect-scale flying robots in controlled laboratories. It is not yet autonomous or field-ready: the prototype receives power through external wires and still needs onboard power, control, sensors, steering and landing capability.
Source checked October 31, 2026. Status describes the evidence in the linked source at the time of review.