
NTU soft robot learns its own motion and stiffness control
What happened
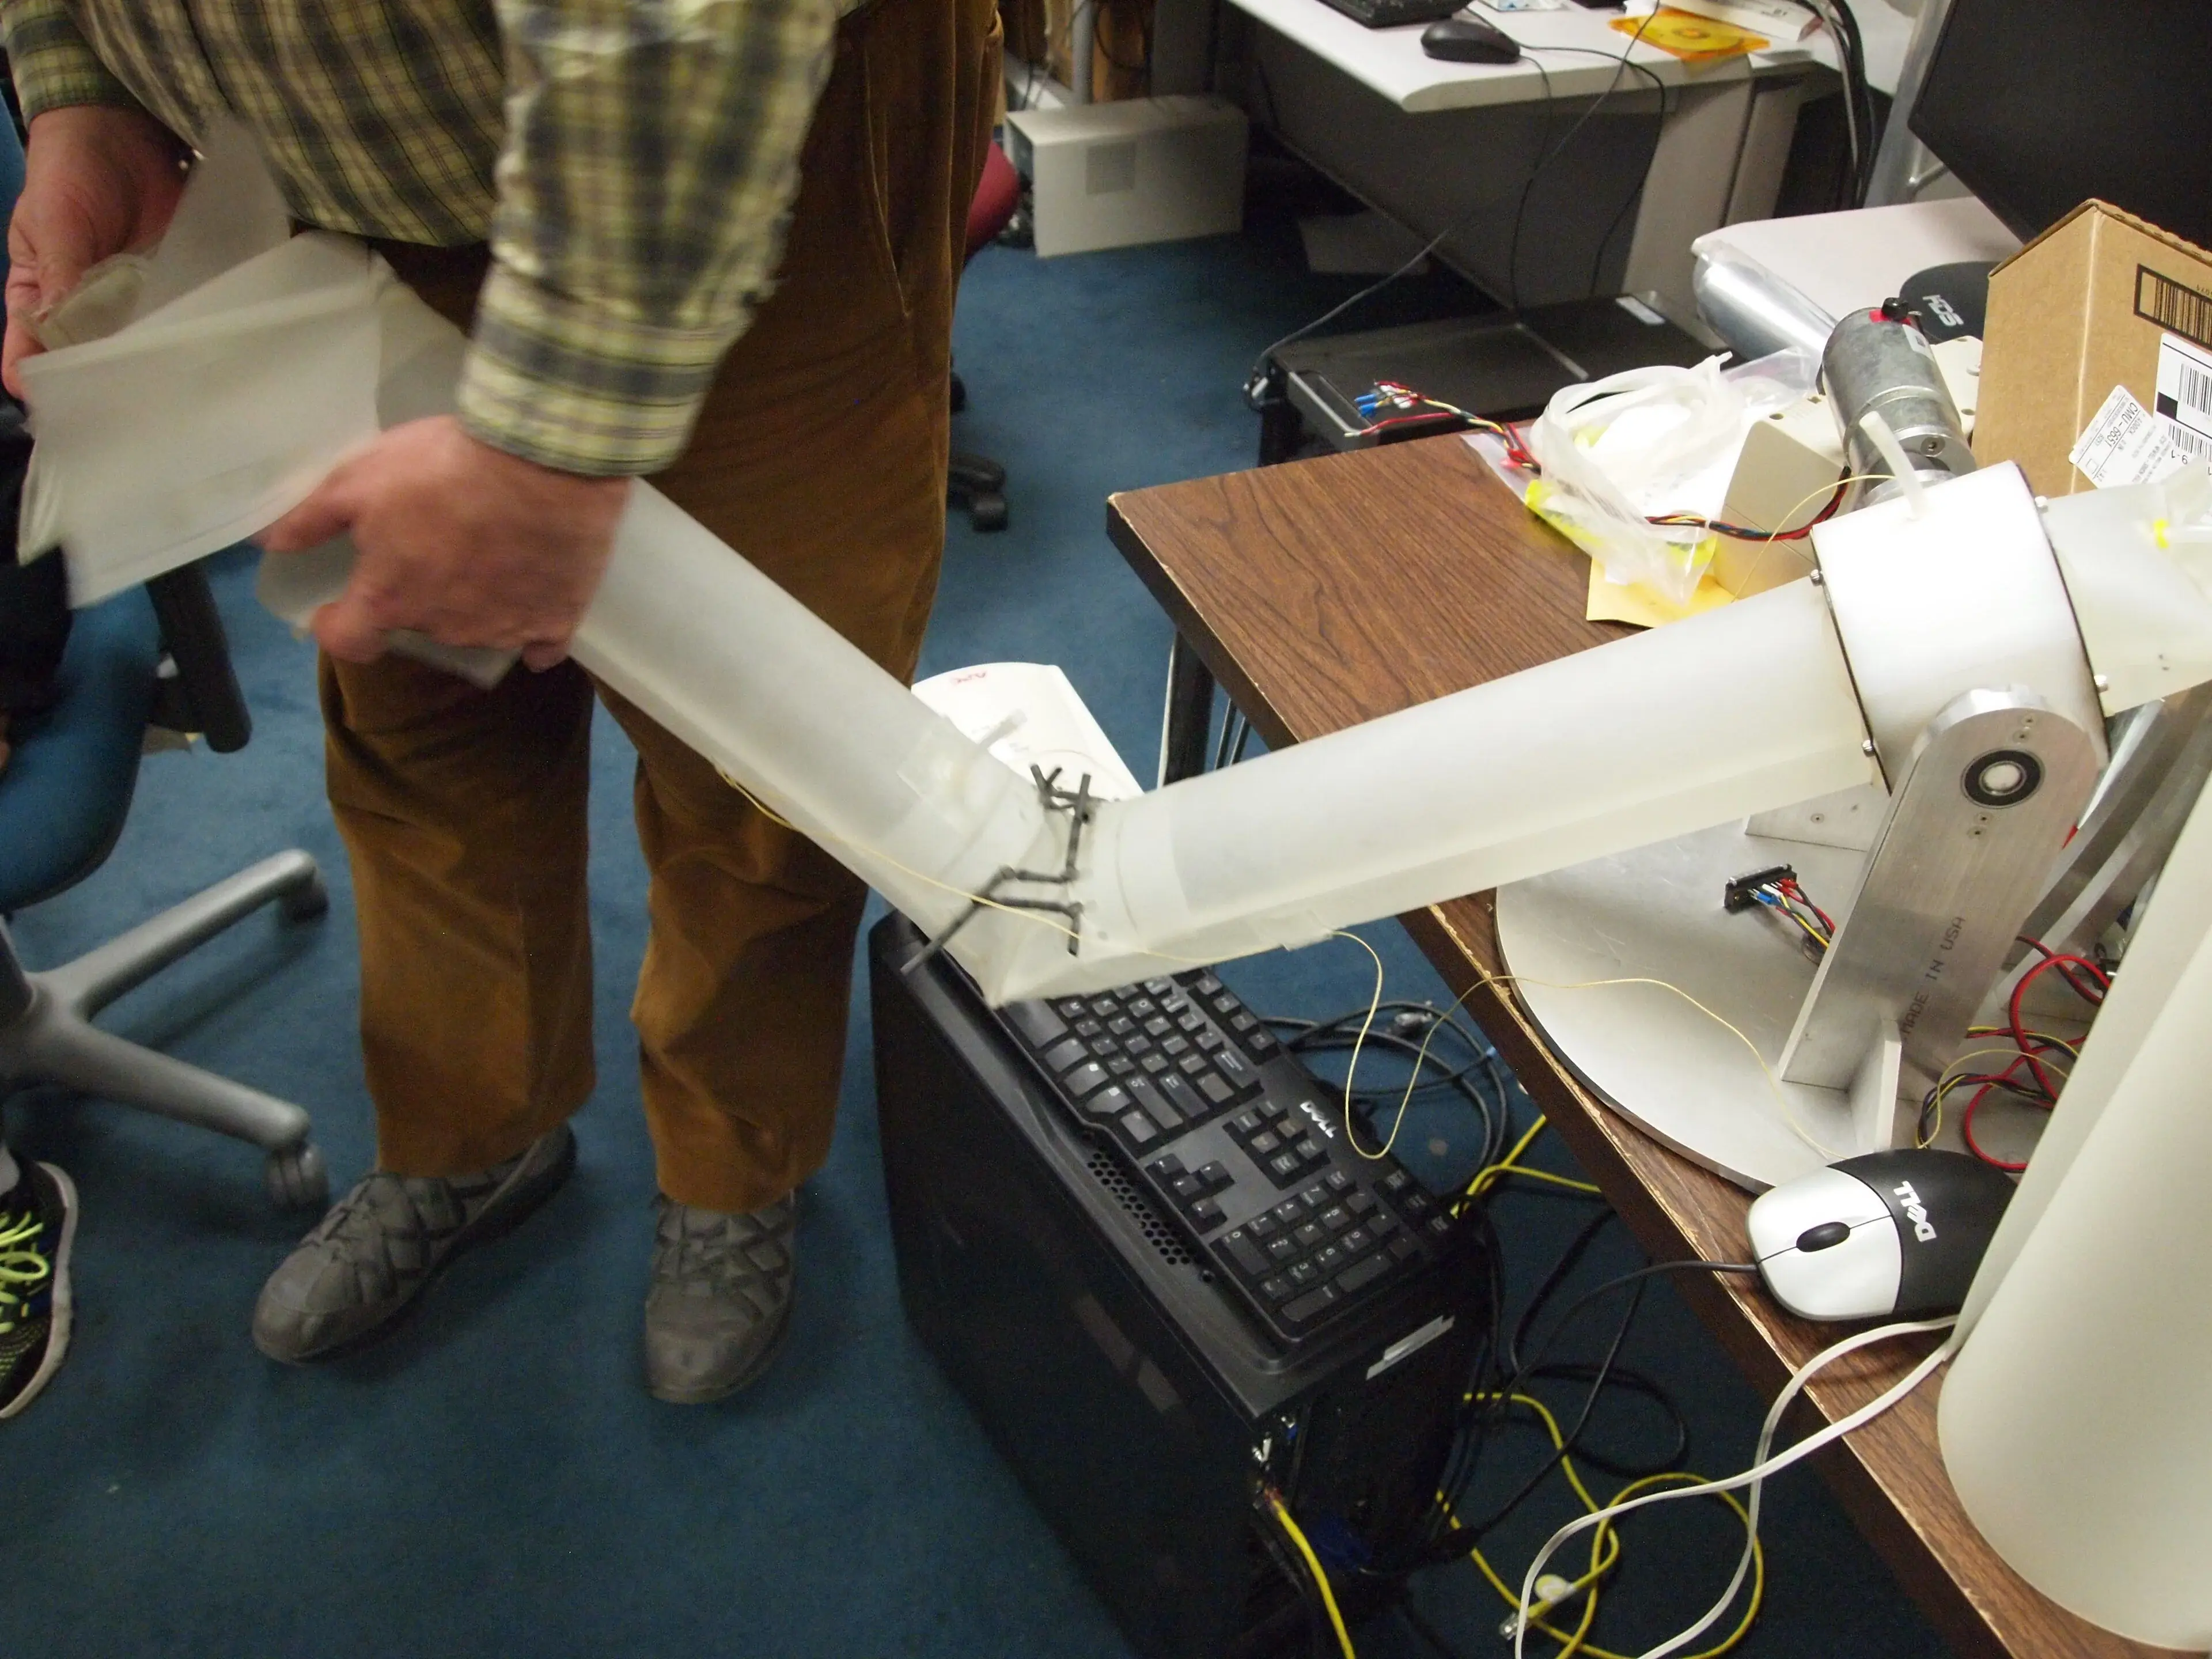
The team used the controller on a pneumatic soft robot for four physical tasks: gripping, sensing object softness, pumping liquid uphill and forming a reconfigurable bridge. After adjustments, the same approach also controlled a mechanically different cable-driven robot under added load and in thick silicone oil. The work was published in Science Advances.
Why it matters
The experiments show that one modeling-and-control approach can coordinate shape and stiffness across different tasks and two actuation designs. They remain controlled laboratory tests, not evidence of autonomous operation in homes, clinics or industry, and transfer still required adaptation for the second robot.
Source checked October 31, 2026. Status describes the evidence in the linked source at the time of review.