
RobotMe summary
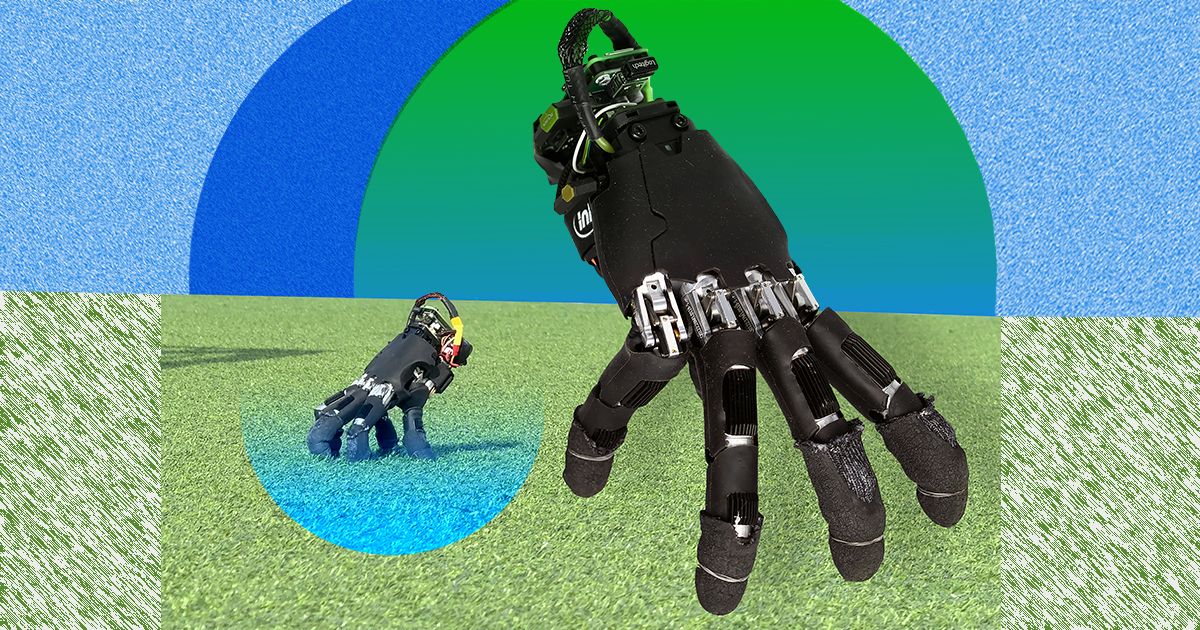
Researchers at ETH Zurich adapted a commercial robotic hand so it can crawl on its fingertips and still manipulate objects. They added a small battery and computer, then trained separate controls in simulation for walking, recovering from falls, and handling objects. The work explores whether a robot component could detach and reach spaces that a full arm cannot.
The research explores whether a hand could detach from a larger robot, move through a tight space on its fingers and still manipulate objects. The reported work combines modified hardware with separate trained behaviors for walking, recovery and handling. It remains a research demonstration, not a deployed industrial hand.