
RobotMe summary
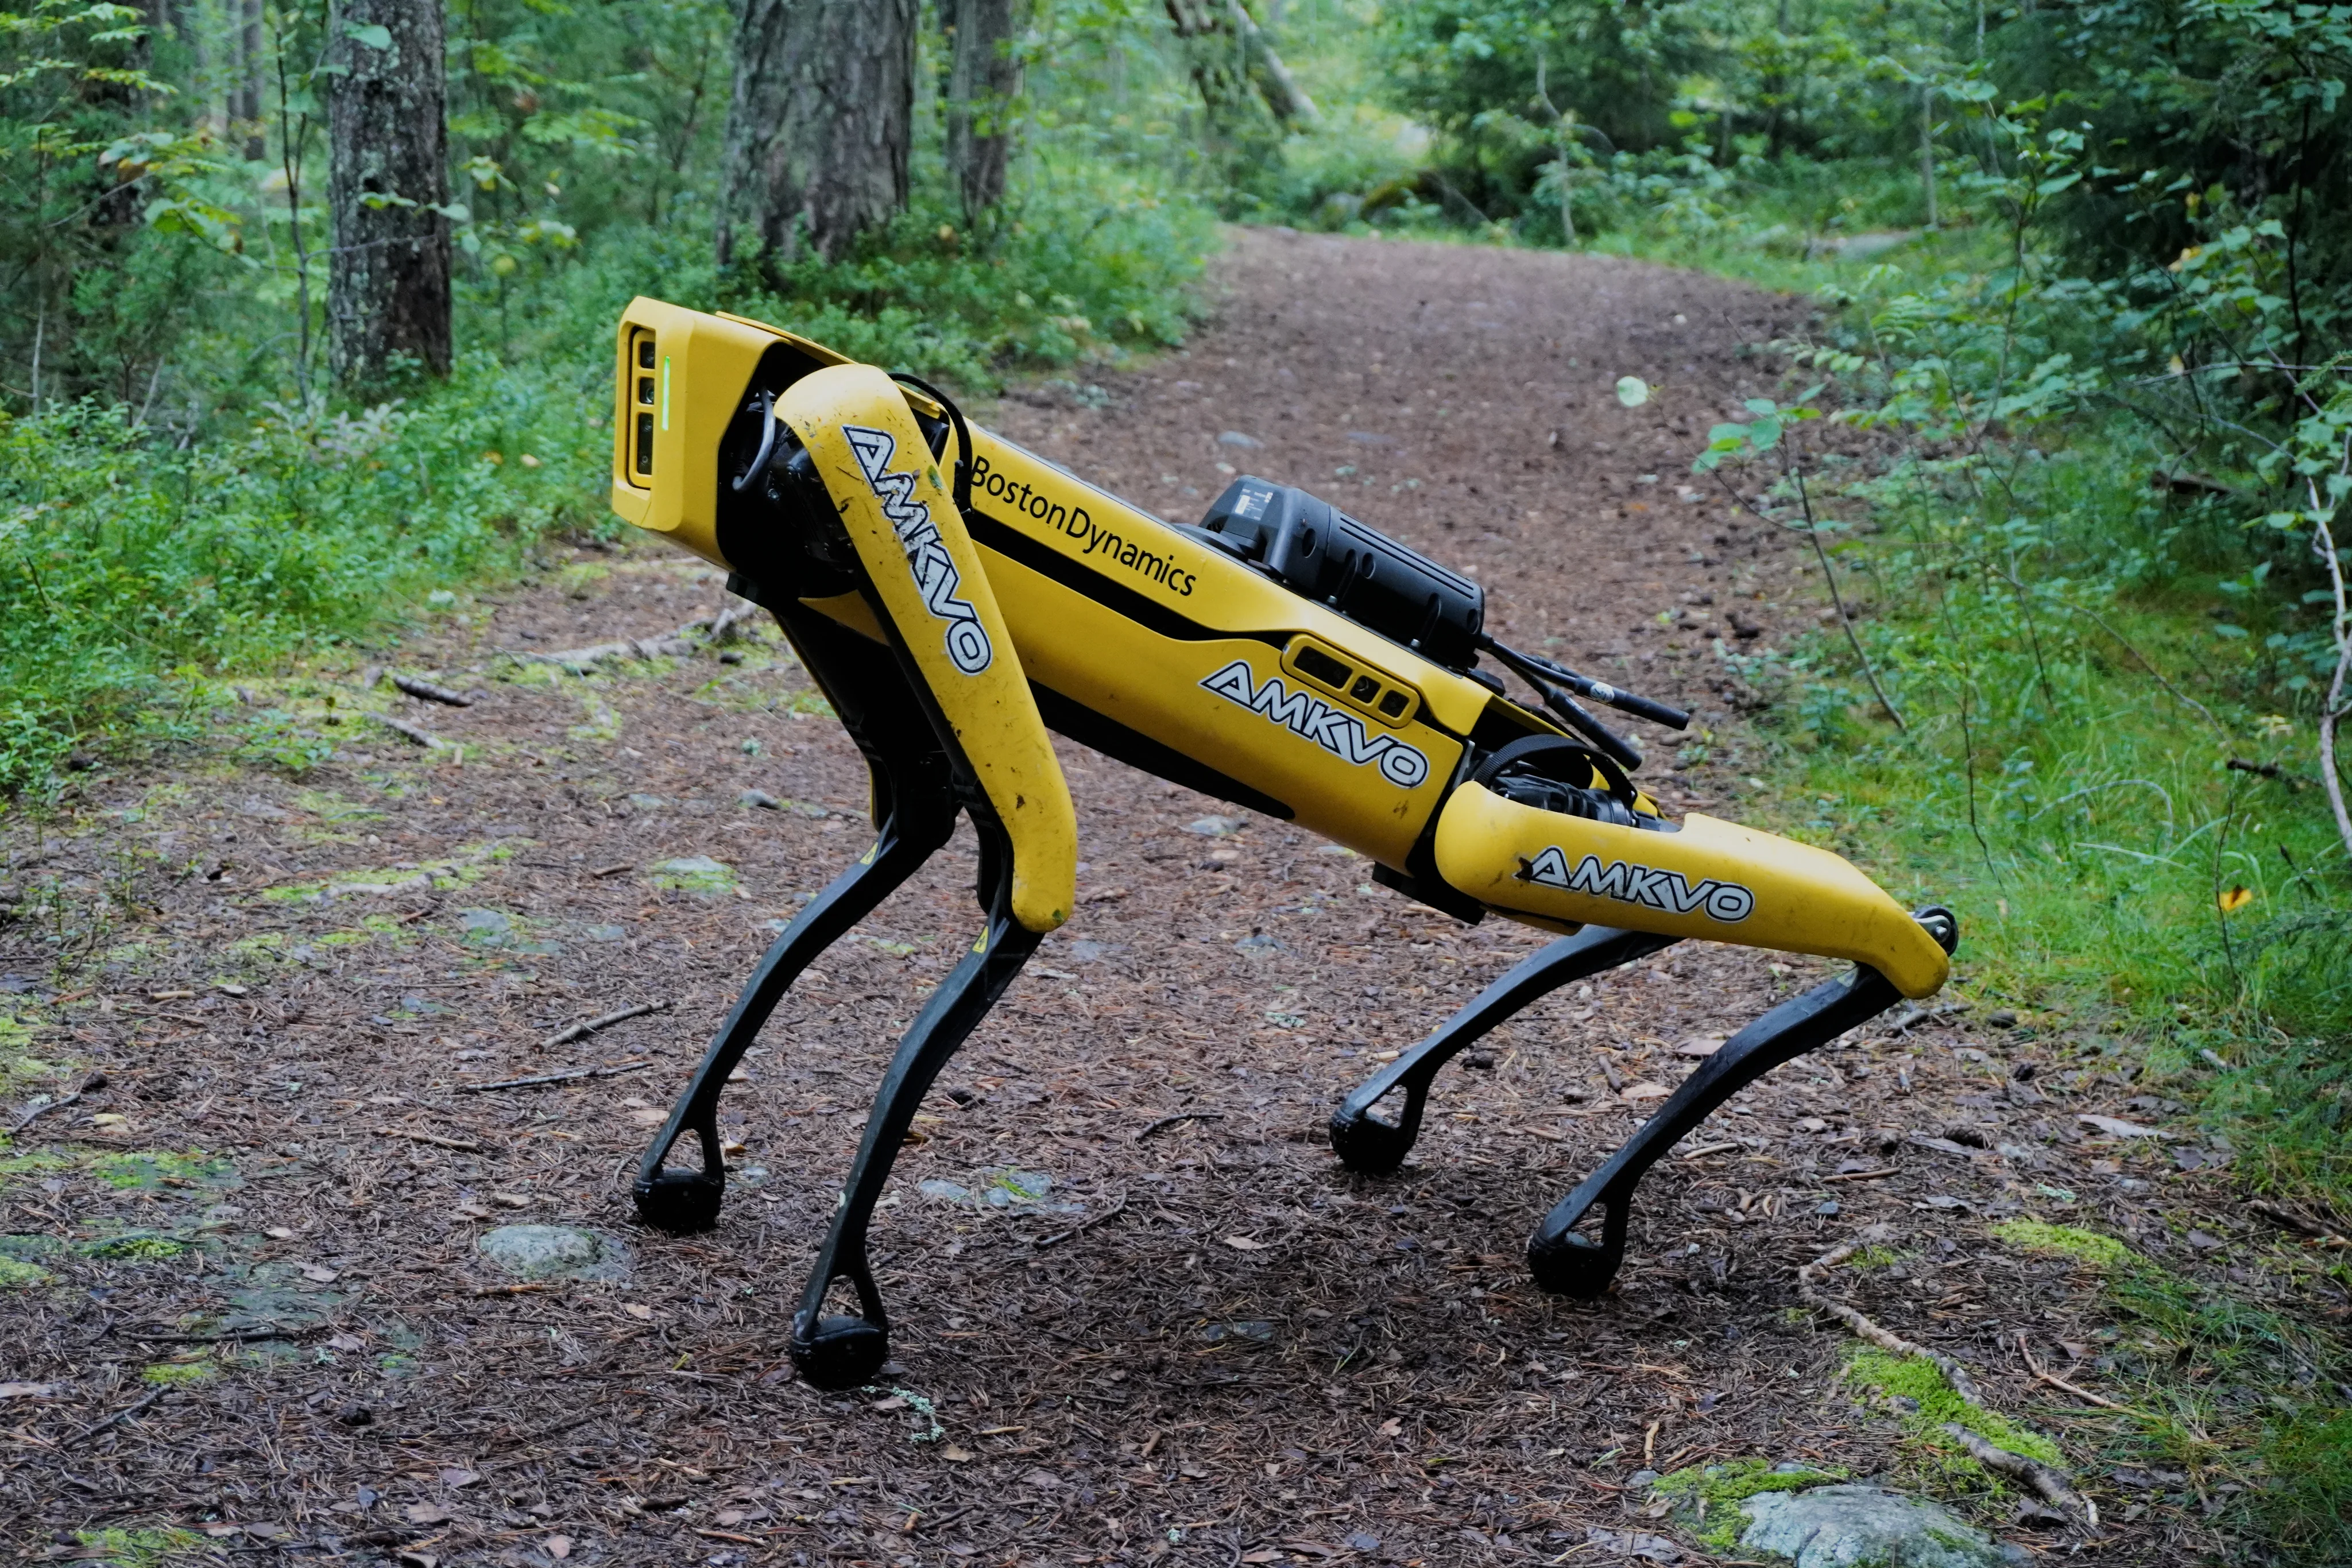
Google describes Gemini 4 Argon as a general-purpose model being tested across robotics tasks, including visual planning, robot control, simulation building, and labeling human or robot motion. Its examples include a Spot robot practicing a trash-bin task in simulation before acting on hardware. The demonstrations and benchmark figures are Google-reported results, not proof that the model can reliably run arbitrary robots in production.
Google’s examples include a Spot robot using a simulated pedal-bin task before acting on hardware, an arm completing a tabletop cleanup task, and tools for building simulation scenes from images or recorded motion. The reported benchmark and demonstrations come from Google; they are selected examples, not independent evidence of general reliability across arbitrary robots.